

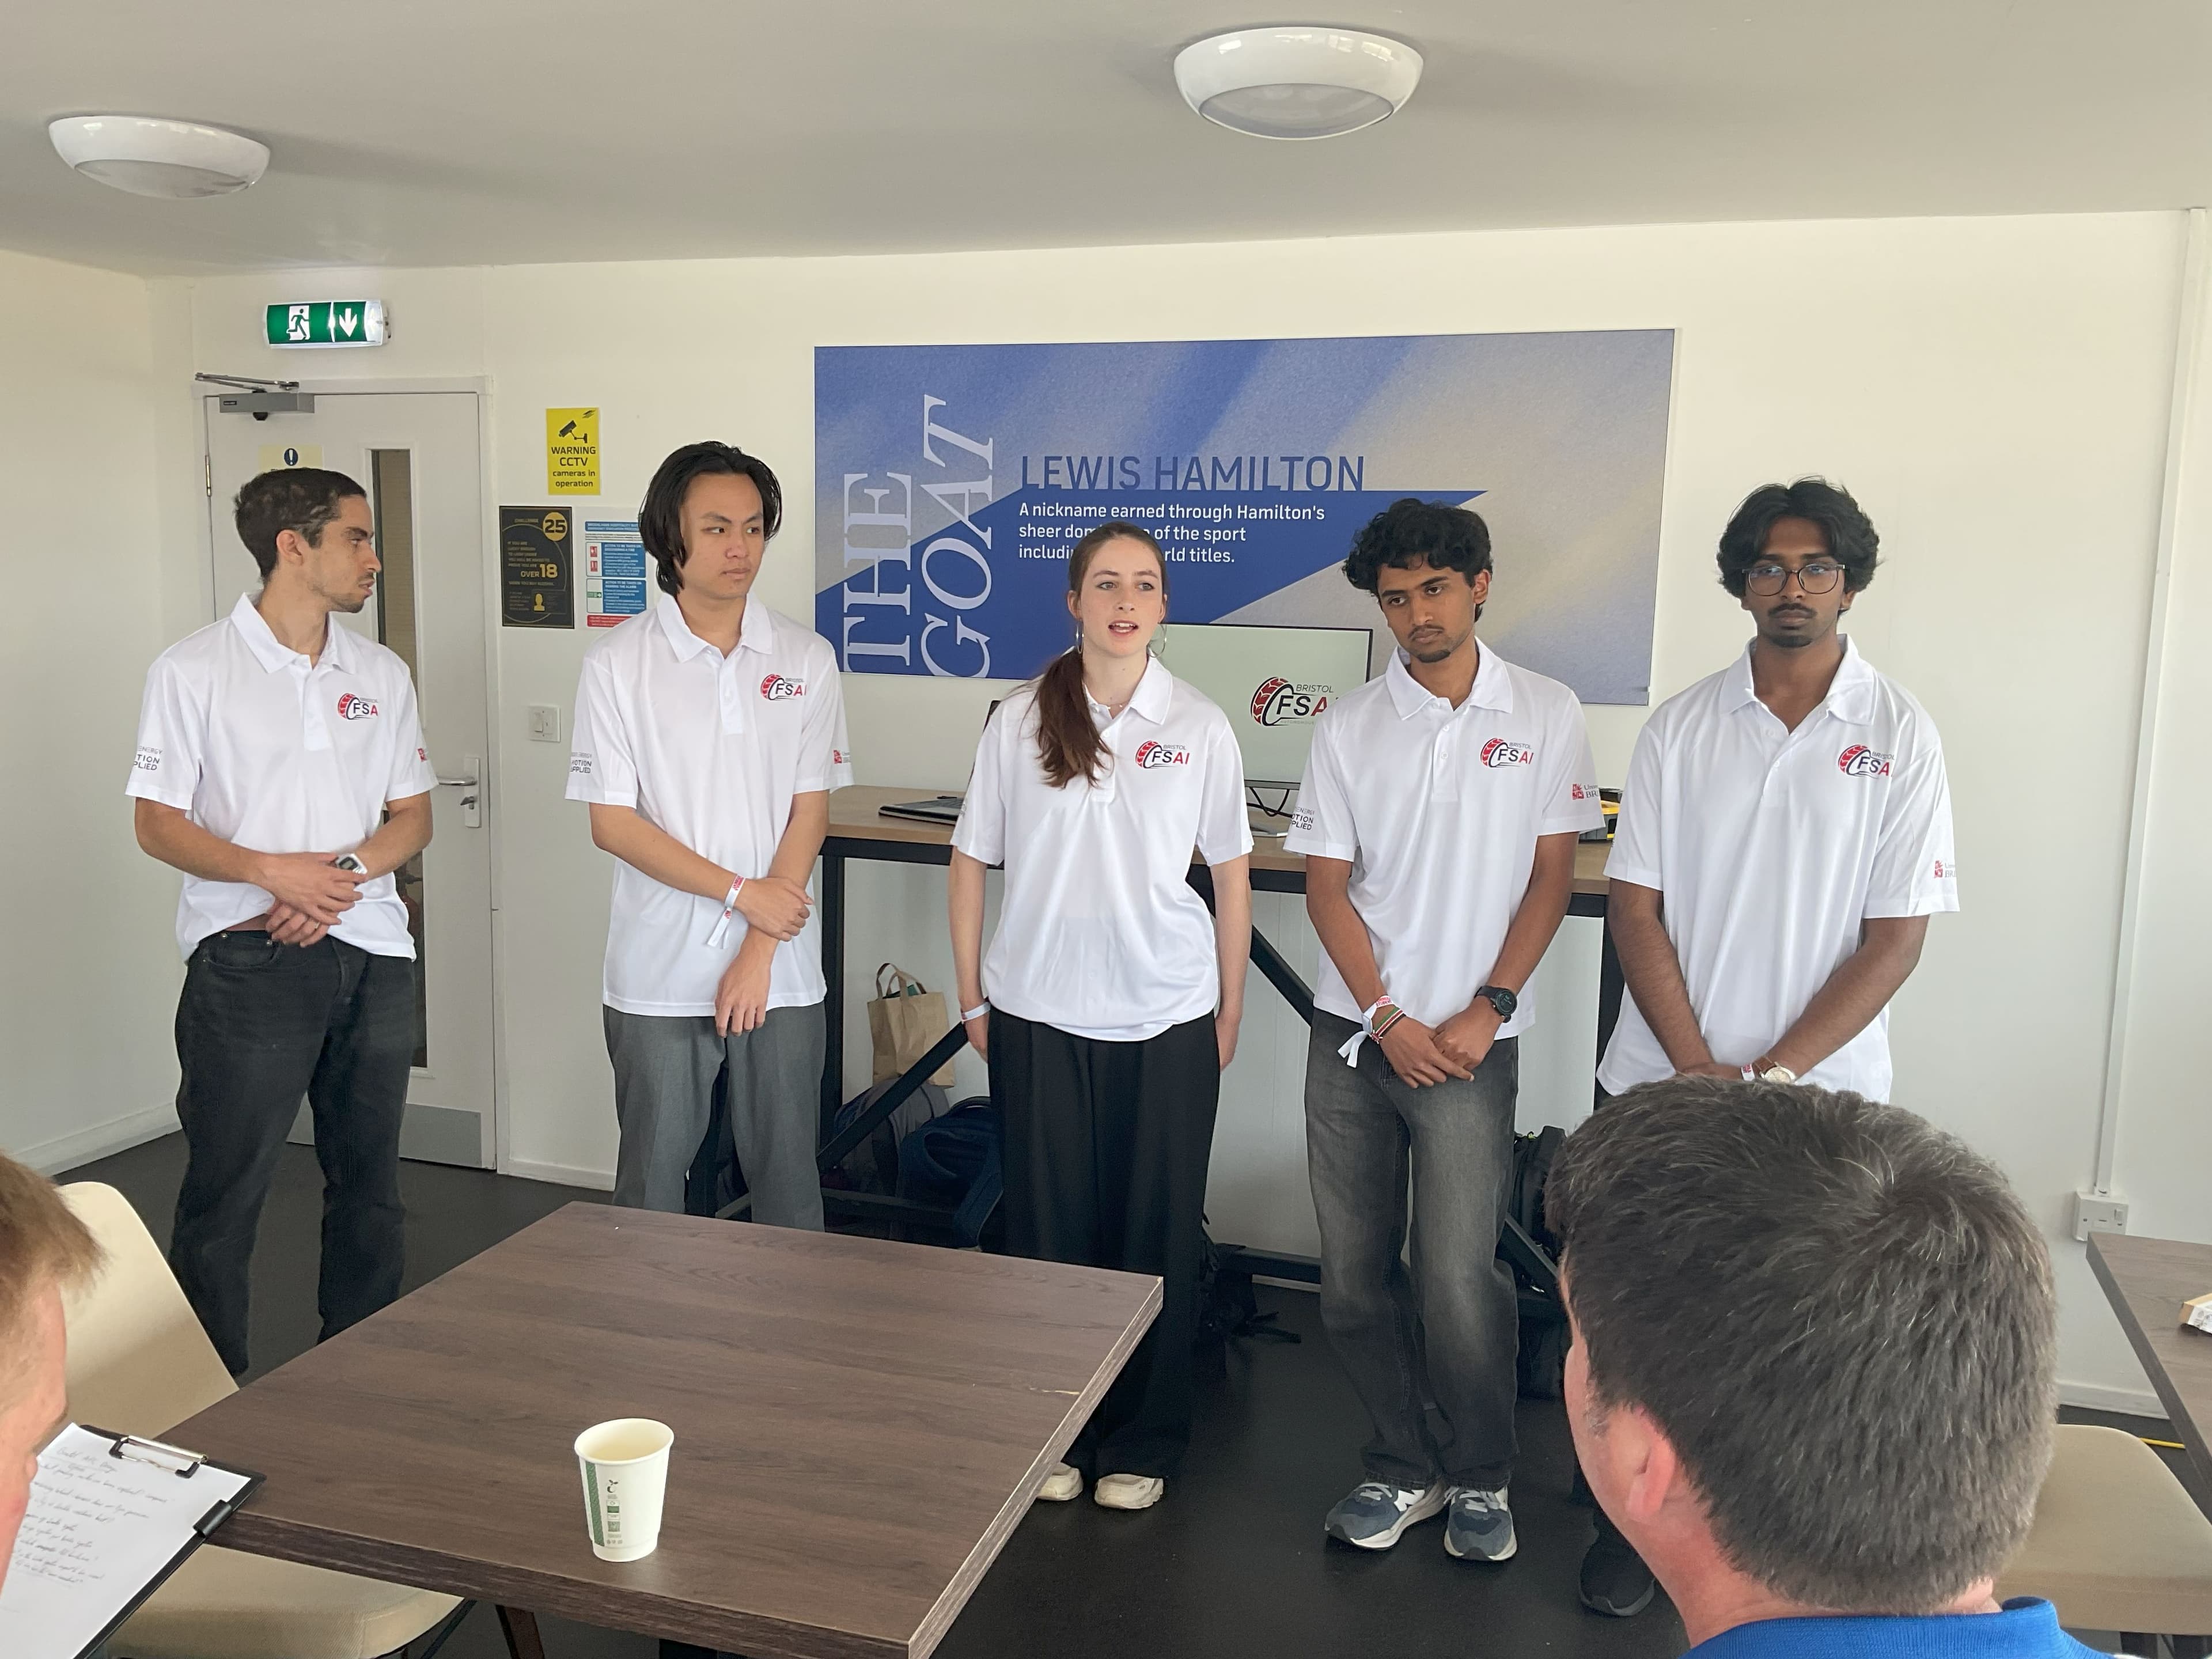
APC (Autonomous Platform Cup)
The APC team builds and integrates our autonomous platform vehicle for the Formula Student AI Autonomous Platform Cup. This is a seperate competition category, introduced in 2026, in which teams design their own driverless vehicles equipped with AI computers, sensors, and low-voltage electric powertrains to compete in FS-AI dynamic events.
We entered this category with a design and concept in 2026. In 2027, we will compete in the dynamic events for the first time.
Focus Areas
- Vehicle design & build: Designing and constructing a purpose-built autonomous platform with low-voltage electric powertrain, meeting APC technical regulations.
- Sensor integration: Mounting and calibrating LiDAR, cameras, IMU, and other sensors on the APC vehicle.
- AI system integration: Integrating the autonomy stack (perception, SLAM, planning & control) onto the vehicle hardware.
- Safety systems: Implementing emergency braking, remote shutdown (RES), and other safety-critical systems required by competition rules.
Practices
- Regulation compliance: Ensuring the vehicle meets all IMechE APC technical rules including wheelbase, braking, and powertrain requirements.
- Test-driven development: Validating systems in simulation and controlled test environments before competition.
- Cross-team collaboration: Working closely with Perception, SLAM, and all other subteams to integrate the full autonomy stack onto the APC vehicle.
Core Team Members
Academic Year 2026-2027

Jessica Vick
Braking System Team Lead
cl25007@bristol.ac.uk
Jacob Da Costa
Mechanical Design Team Lead
Alex Fann
Powertrain Team Lead

Youssef
Electrical Systems Team Lead